A Novel Pet Trajectory Prediction Method for Intelligent Plant Cultivation Robot
Featured in:
IEEE Sensors Letters
Authors:
Zihan Jiang, Bo Jin and Yichen Song
Abstract
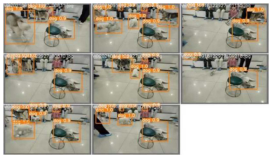
Intelligent plant cultivation robots will have certain working obstacles due to various moving objects, such as pets. This letter studies how to predict the trajectory of pets to avoid collisions. In previous intelligent plant cultivation robot systems, target-tracking technology was used to track pets and avoid collisions. However, collisions often occur even after tracking the trajectory of the pet because the trajectory of the pet’s movement is difficult to determine. Therefore, the Informer algorithm is used to predict the trajectory of pets in this letter. It is presented that collisions can be avoided based on the predicted trajectory. Experimental results on the data set show that this algorithm has better accuracy than most common algorithms, so trajectory prediction based on this algorithm can make the robot avoid obstacles better. Finally, by verifying two data sets, the public data set and the self-made data set, it is determined that the performance of the proposed method is optimized by 3%–50% compared with other methods.
Citation
Zihan Jiang, Bo Jin and Yichen Song (2023). A Novel Pet Trajectory Prediction Method for Intelligent Plant Cultivation Robot. IEEE Sensors Letters, 7(2), 1-4. DOI: 10.1109/LSENS.2023.3238468
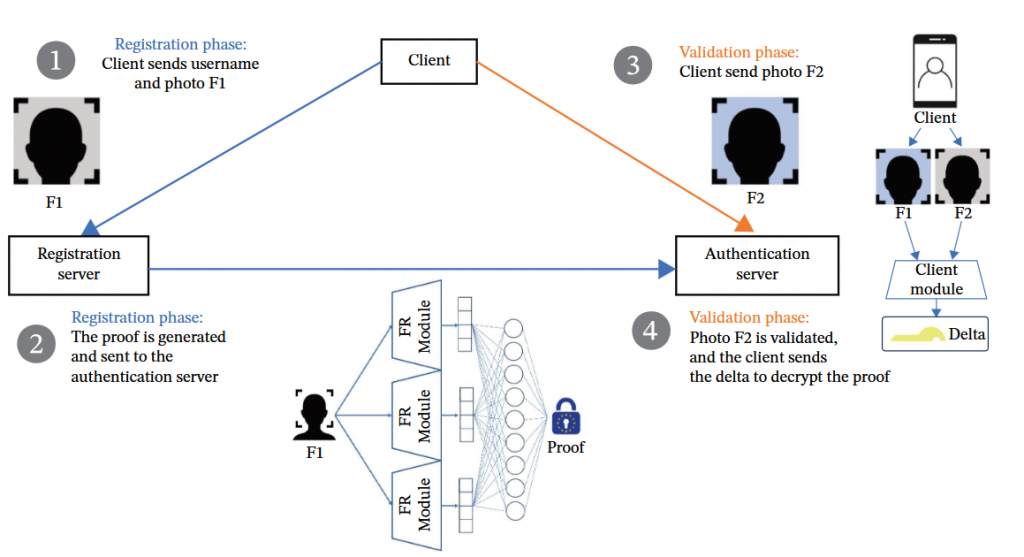
Towards Secure Biometric Solutions: A Multifactor Authentication Framework for Facial Recognition While Protecting User Data
Authors: José Silva; Ajnas Muhammed; Aniana Cruz; Bruno Sousa; Nuno Gonçalves
Featured in: IET Biometrics Volume 2026, Issue 1
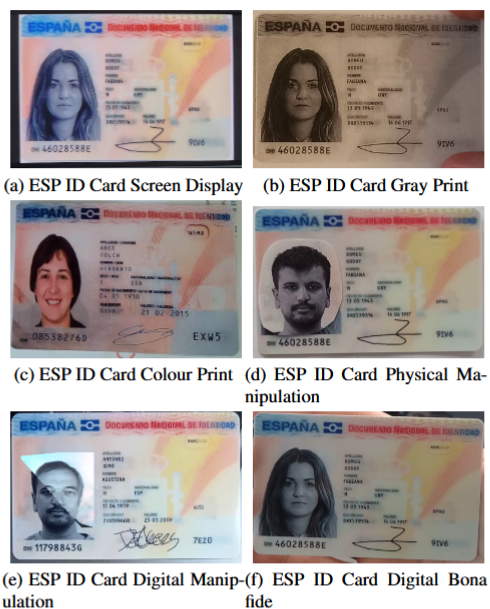
Second Competition on Presentation Attack Detection on ID Card
Authors: Juan E Tapia; Mario Nieto; Juan M Espin; Alvaro S Rocamora; Javier Barrachina; Naser Damer; Christoph Busch; Marija Ivanovska; Leon Todorov; Renat Khizbullin; Lazar Lazarevich; Aleksei Grishin; Daniel Schulz; Sebastian Gonzalez; Amir Mohammadi; Ketan Kotwal; Sebastien Marcel; Raghavendra Mudgalgundurao; Kiran Raja; Patrick Schuch; Sushrut Patwardhan; Raghavendra Ramachandra; Pedro Couto Pereira; Joao Ribeiro Pinto; Mariana Xavier; Andrés Valenzuela; Rodrigo Lara; Borut Batagelj; Marko Peterlin; Peter Peer; Ajnas Muhammed; Diogo Nunes; Nuno Gonçalves
Featured in: 2025 IEEE International Joint Conference on Biometrics
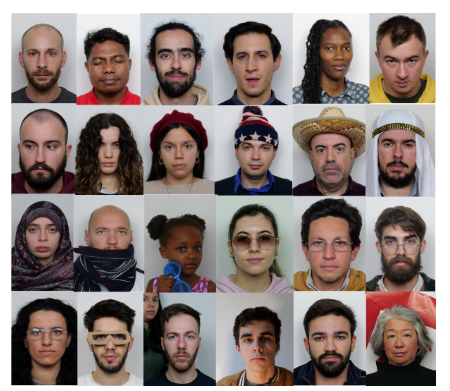
DFIC: Towards a balanced facial image dataset for automatic ICAO compliance verification
Authors: Nuno Gonçalves; Diogo Nunes; Carla Guerra; João Marcos
Featured in: Submited to: ArXiv
suggested news
VIS Team will host a session presenting the...
Paper presented at NeurIPS 2025
VIS Team has presented workshop at the 12th...
RECENT PROJECTS
FACING2 – Face Image Understanding
VISUAL-ID – Unique Visual Identities in Graphics, Images and Faces
UniqueMark
Institute of Systems and Robotics Department of Electrical and Computers Engineering University of Coimbra