Type of Publication

Conference Papers

Date:

9 /

2000

Status

Published

A Study on Static Gaits for a Four Legged Robot

Featured in:

CONTROL’2000, Cambridge, UK

Authors:

Carlos Queiroz, Nuno Gonçalves and Paulo Menezes

Abstract

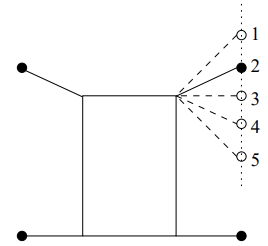
This paper describes the study of algorithms to obtain static or marginally static gaits. Some of them are similar to the walking gaits used by some mammals, e.g. horses, cows, etc.. It describes a methodology for deriving the inverse kinematics of a quadruped. It then explains an algorithm which implements an exhaustive search of static gaits using a formal description of the robot. A similar method is applied to implement on a quadruped robot the most common walking gaits seen in animals. 1625 stable and 400 marginally stable robot configurations were found using our stability test algorithm. Using these results in the first algorithm, 848 static gaits and 141424 marginally static gaits were found. By applying the second algorithm were found 15 walking gaits and were analysed to determine their stability margins (which is the minor of the minimum distance of the mass centre to the border of the supporting polygon formed by the legs in contact with the ground). The method can be used to determine similar gaits on walking systems with any number of legs.

Citation
Carlos Queiroz, Nuno Gonçalves and Paulo Menezes (1999). A study on static gaits for a four leg robot. In Proc. Control-UK ACC Int. Conf. Control (pp. 1-6).
Related Content

Researcher Coordinator, VIS TEAM Leader
No tagged content to show

RECENT PUBLICATIONS

Biometrics under attack: On provenance, trust and threat robustness

Authors: Guilherme Schardong; Tiago Novello; Luiz Silva; Nuno Gonçalves
Featured in: 39th Conference on Graphics, Patterns and Images

STATISTICAL ANALYSIS OF RETINAL ARTERIAL NETWORKS: Graph-Based Radiomics Framework

Authors: Ofélio Jorreia; Nuno Gonçalves, Rui Cortesão
Featured in: IEEE Access

MorphGuard: Morph Specific Margin Loss for Enhancing Robustness to Face Morphing Attacks

Authors: Iurii Medvedev; Ajnas Muhammed; Nuno Gonçalves
Featured in: 11th International Conference on Computer Vision & Image Processing (CVIP 2026)

suggested news

VIS Team will host a session presenting the...
Paper presented at NeurIPS 2025
VIS Team has presented workshop at the 12th...

RECENT PROJECTS

FACING2 – Face Image Understanding
VISUAL-ID – Unique Visual Identities in Graphics, Images and Faces
UniqueMark

Institute of Systems and Robotics Department of Electrical and Computers Engineering University of Coimbra