Reducing Overconfidence Predictions in Autonomous Driving Perception
Featured in:
IEEE Access, vol. 10, pp. 54805-54821, 2022
Authors:
Gledson Melotti, Cristiano Premebida, Jordan J. Bird, Diego R. Faria and Nuno Gonçalves
Abstract
In state-of-the-art deep learning for object recognition, Softmax and Sigmoid layers are most commonly employed as the predictor outputs. Such layers often produce overconfidence predictions rather than proper probabilistic scores, which can thus harm the decision-making of ‘critical’ perception systems applied in autonomous driving and robotics. Given this, we propose a probabilistic approach based on distributions calculated out of the Logit layer scores of pre-trained networks which are then used to constitute new decision layers based on Maximum Likelihood ( ML ) and Maximum a-Posteriori (MAP) inference. We demonstrate that the hereafter called ML and MAP layers are more suitable for probabilistic interpretations than Softmax and Sigmoid-based predictions for object recognition. We explore distinct sensor modalities via RGB images and LiDARs (RV: range-view) data from the KITTI and Lyft Level-5 datasets, where our approach shows promising performance compared to the usual Softmax and Sigmoid layers, with the benefit of enabling interpretable probabilistic predictions. Another advantage of the approach introduced in this paper is that the so-called ML and MAP layers can be implemented in existing trained networks, that is, the approach benefits from the output of the Logit layer of pre-trained networks. Thus, there is no need to carry out a new training phase since the ML and MAP layers are used in the test/prediction phase. The Classification results are presented using reliability diagrams, while detection results are illustrated using precision-recall curves.
Citation
Gledson Melotti, Cristiano Premebida, Jordan J. Bird, Diego R. Faria and Nuno Gonçalves (2022). Reducing overconfidence predictions in autonomous driving perception. IEEE Access, 10, 54805-54821. DOI: 10.1109/ACCESS.2022.3175195
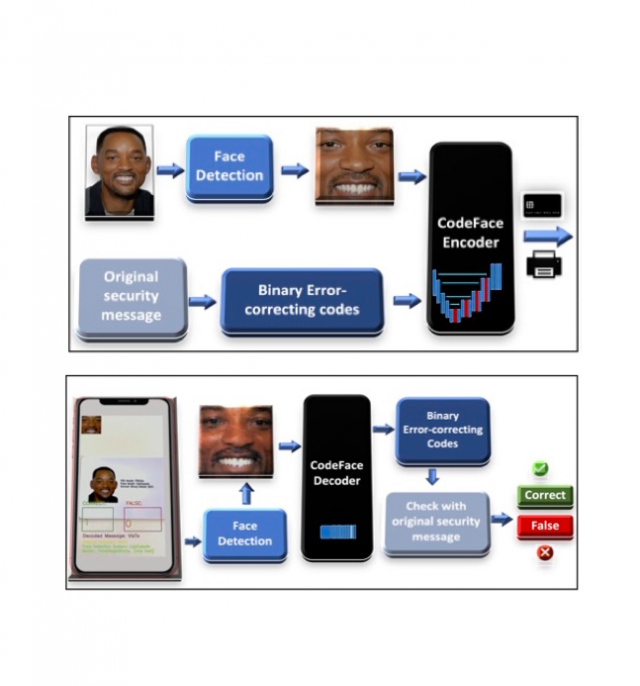
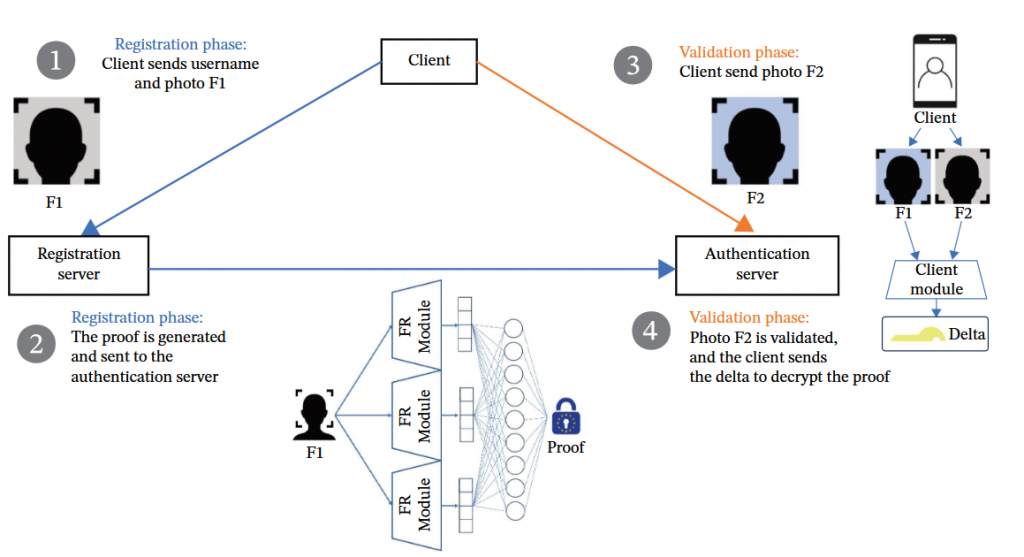
Towards Secure Biometric Solutions: A Multifactor Authentication Framework for Facial Recognition While Protecting User Data
Authors: José Silva; Ajnas Muhammed; Aniana Cruz; Bruno Sousa; Nuno Gonçalves
Featured in: IET Biometrics Volume 2026, Issue 1
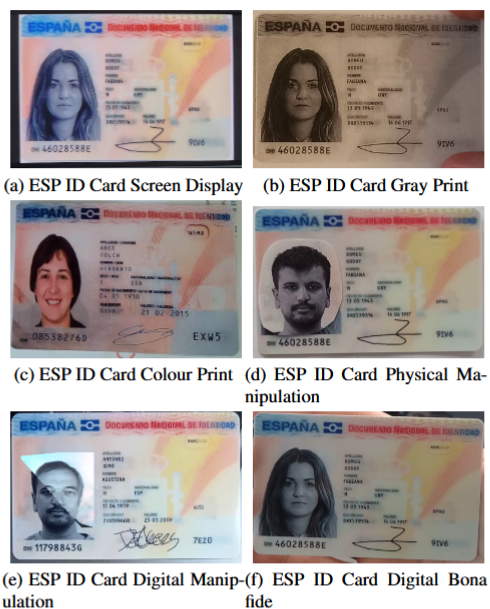
Second Competition on Presentation Attack Detection on ID Card
Authors: Juan E Tapia; Mario Nieto; Juan M Espin; Alvaro S Rocamora; Javier Barrachina; Naser Damer; Christoph Busch; Marija Ivanovska; Leon Todorov; Renat Khizbullin; Lazar Lazarevich; Aleksei Grishin; Daniel Schulz; Sebastian Gonzalez; Amir Mohammadi; Ketan Kotwal; Sebastien Marcel; Raghavendra Mudgalgundurao; Kiran Raja; Patrick Schuch; Sushrut Patwardhan; Raghavendra Ramachandra; Pedro Couto Pereira; Joao Ribeiro Pinto; Mariana Xavier; Andrés Valenzuela; Rodrigo Lara; Borut Batagelj; Marko Peterlin; Peter Peer; Ajnas Muhammed; Diogo Nunes; Nuno Gonçalves
Featured in: 2025 IEEE International Joint Conference on Biometrics
DFIC: Towards a balanced facial image dataset for automatic ICAO compliance verification
Authors: Nuno Gonçalves; Diogo Nunes; Carla Guerra; João Marcos
Featured in: Submited to: ArXiv
suggested news
VIS Team will host a session presenting the...
Paper presented at NeurIPS 2025
VIS Team has presented workshop at the 12th...
RECENT PROJECTS
FACING2 – Face Image Understanding
VISUAL-ID – Unique Visual Identities in Graphics, Images and Faces
UniqueMark
Institute of Systems and Robotics Department of Electrical and Computers Engineering University of Coimbra