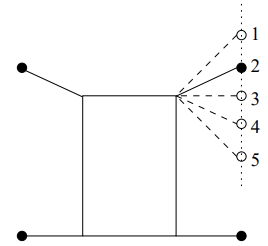
This paper describes the study of algorithms to obtain static or marginally static gaits. Some of them are similar to the walking gaits used by some mammals, e.g. horses, cows, etc.. It describes a methodology for deriving the inverse kinematics of a quadruped. It then explains an algorithm which implements an exhaustive search of static gaits using a formal description of the robot. A similar method is applied to implement on a quadruped robot the most common walking gaits seen in animals. 1625 stable and 400 marginally stable robot configurations were found using our stability test algorithm. Using these results in the first algorithm, 848 static gaits and 141424 marginally static gaits were found. By applying the second algorithm were found 15 walking gaits and were analysed to determine their stability margins (which is the minor of the minimum distance of the mass centre to the border of the supporting polygon formed by the legs in contact with the ground). The method can be used to determine similar gaits on walking systems with any number of legs.
Citation
Carlos Queiroz, Nuno Gonçalves and Paulo Menezes (1999). A study on static gaits for a four leg robot. In Proc. Control-UK ACC Int. Conf. Control (pp. 1-6).
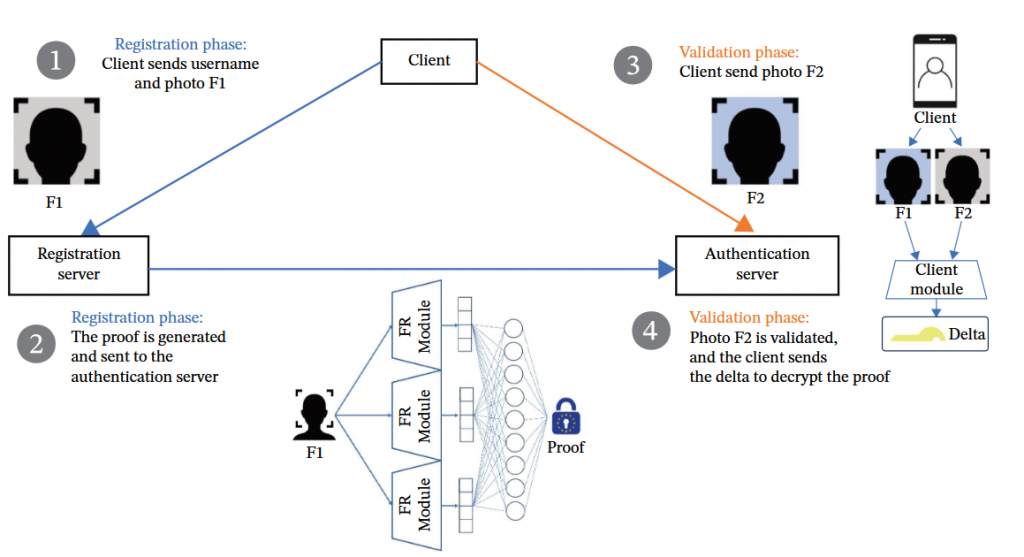
Towards Secure Biometric Solutions: A Multifactor Authentication Framework for Facial Recognition While Protecting User Data
Authors: José Silva; Ajnas Muhammed; Aniana Cruz; Bruno Sousa; Nuno Gonçalves
Featured in: IET Biometrics Volume 2026, Issue 1
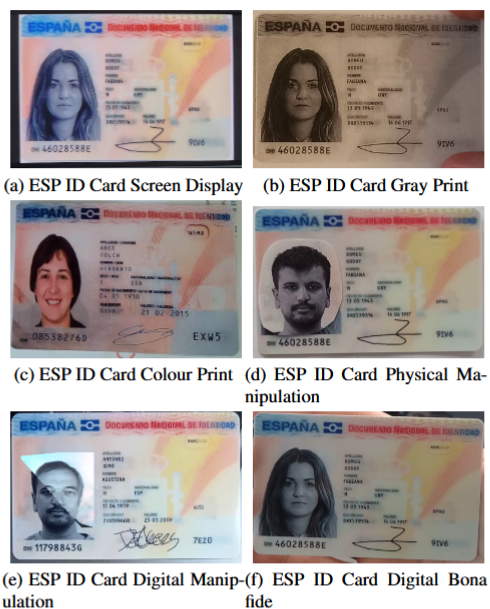
Second Competition on Presentation Attack Detection on ID Card
Authors: Juan E Tapia; Mario Nieto; Juan M Espin; Alvaro S Rocamora; Javier Barrachina; Naser Damer; Christoph Busch; Marija Ivanovska; Leon Todorov; Renat Khizbullin; Lazar Lazarevich; Aleksei Grishin; Daniel Schulz; Sebastian Gonzalez; Amir Mohammadi; Ketan Kotwal; Sebastien Marcel; Raghavendra Mudgalgundurao; Kiran Raja; Patrick Schuch; Sushrut Patwardhan; Raghavendra Ramachandra; Pedro Couto Pereira; Joao Ribeiro Pinto; Mariana Xavier; Andrés Valenzuela; Rodrigo Lara; Borut Batagelj; Marko Peterlin; Peter Peer; Ajnas Muhammed; Diogo Nunes; Nuno Gonçalves
Featured in: 2025 IEEE International Joint Conference on Biometrics
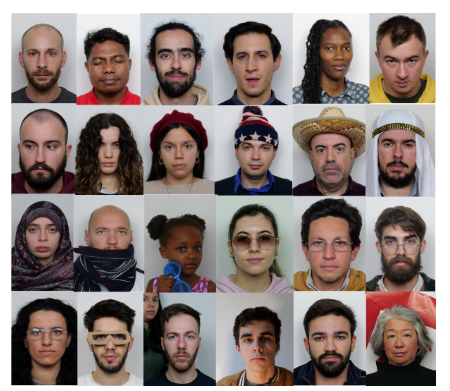
DFIC: Towards a balanced facial image dataset for automatic ICAO compliance verification
Authors: Nuno Gonçalves; Diogo Nunes; Carla Guerra; João Marcos
Featured in: Submited to: ArXiv
suggested news
VIS Team will host a session presenting the...
Paper presented at NeurIPS 2025
VIS Team has presented workshop at the 12th...
RECENT PROJECTS
FACING2 – Face Image Understanding
VISUAL-ID – Unique Visual Identities in Graphics, Images and Faces
UniqueMark
Institute of Systems and Robotics Department of Electrical and Computers Engineering University of Coimbra