Linear solution for the pose estimation of noncentral catadioptric systems
Featured in:
2007 IEEE 11th International Conference on Computer Vision Workshops, Rio de Janeiro, Brazil
Authors:
Nuno Gonçalves and Helder Araújo
Abstract
This paper presents a linear method to estimate the pose of a noncentral catadioptric system with a quadric shaped mirror in relation to a world reference frame (or local reference frame without loss of generality). The vision system is assumed to be calibrated. The method uses also as input data the structure of the scene. It is proved that any reflection point should belong to an analytical quadric that intersects the mirror quadric itself. This constraint can be written linearly in the 3D scene point coordinates (in the camera reference frame). The unknown pose screw transformation that relates camera and world reference frames can then be used in the linear model, allowing for the construction of a linear equation in the pose transformation elements. Additional constraints are used to force the estimated rotation elements to build an orthogonal matrix. Tests with simulated data and also on real images with different mirrors proved the method to be consistent and to estimate the pose accurately. However, it was also observed that the method is sensitive to noise. The results are compared with another method.
Citation
Nuno Gonçalves and Helder Araújo (2007, October). Linear solution for the pose estimation of noncentral catadioptric systems. In 2007 IEEE 11th International Conference on Computer Vision (pp. 1-7). IEEE. DOI: 10.1109/ICCV.2007.4409197
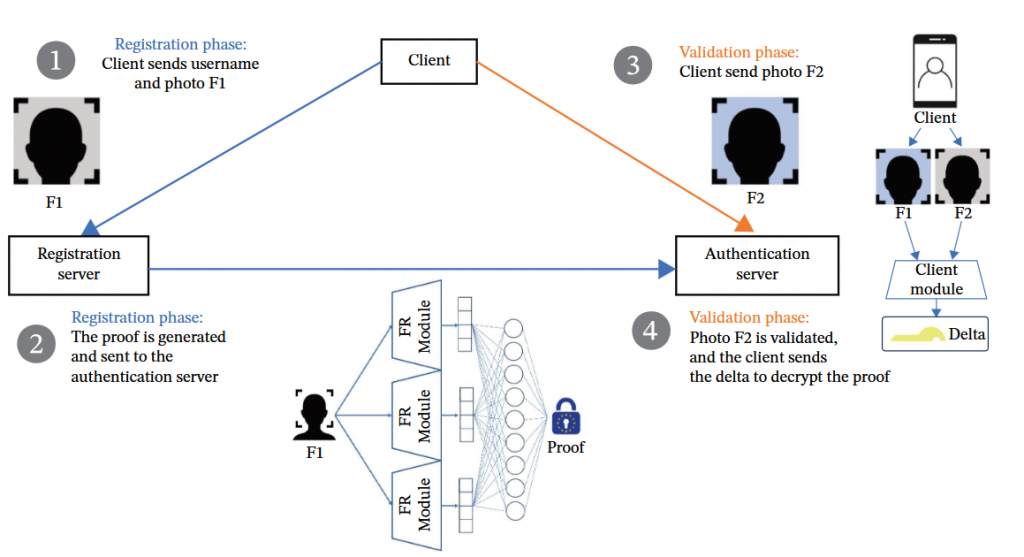
Towards Secure Biometric Solutions: A Multifactor Authentication Framework for Facial Recognition While Protecting User Data
Authors: José Silva; Ajnas Muhammed; Aniana Cruz; Bruno Sousa; Nuno Gonçalves
Featured in: IET Biometrics Volume 2026, Issue 1
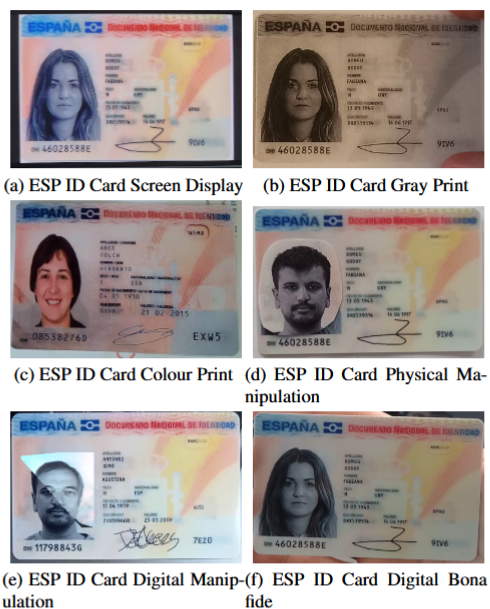
Second Competition on Presentation Attack Detection on ID Card
Authors: Juan E Tapia; Mario Nieto; Juan M Espin; Alvaro S Rocamora; Javier Barrachina; Naser Damer; Christoph Busch; Marija Ivanovska; Leon Todorov; Renat Khizbullin; Lazar Lazarevich; Aleksei Grishin; Daniel Schulz; Sebastian Gonzalez; Amir Mohammadi; Ketan Kotwal; Sebastien Marcel; Raghavendra Mudgalgundurao; Kiran Raja; Patrick Schuch; Sushrut Patwardhan; Raghavendra Ramachandra; Pedro Couto Pereira; Joao Ribeiro Pinto; Mariana Xavier; Andrés Valenzuela; Rodrigo Lara; Borut Batagelj; Marko Peterlin; Peter Peer; Ajnas Muhammed; Diogo Nunes; Nuno Gonçalves
Featured in: 2025 IEEE International Joint Conference on Biometrics
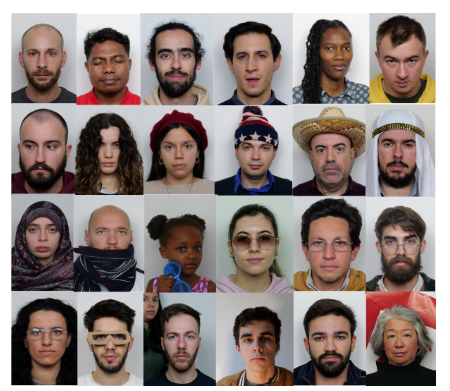
DFIC: Towards a balanced facial image dataset for automatic ICAO compliance verification
Authors: Nuno Gonçalves; Diogo Nunes; Carla Guerra; João Marcos
Featured in: Submited to: ArXiv
suggested news
VIS Team will host a session presenting the...
Paper presented at NeurIPS 2025
VIS Team has presented workshop at the 12th...
RECENT PROJECTS
FACING2 – Face Image Understanding
VISUAL-ID – Unique Visual Identities in Graphics, Images and Faces
UniqueMark
Institute of Systems and Robotics Department of Electrical and Computers Engineering University of Coimbra