Multimodal Deep-Learning for Object Recognition Combining Camera and LIDAR Data
Featured in:
2020 IEEE International Conference on Autonomous Robot Systems and Competitions, Ponta Delgada, Portugal
Authors:
Gledson Melotti, Cristiano Premebida and Nuno Gonçalves
Abstract
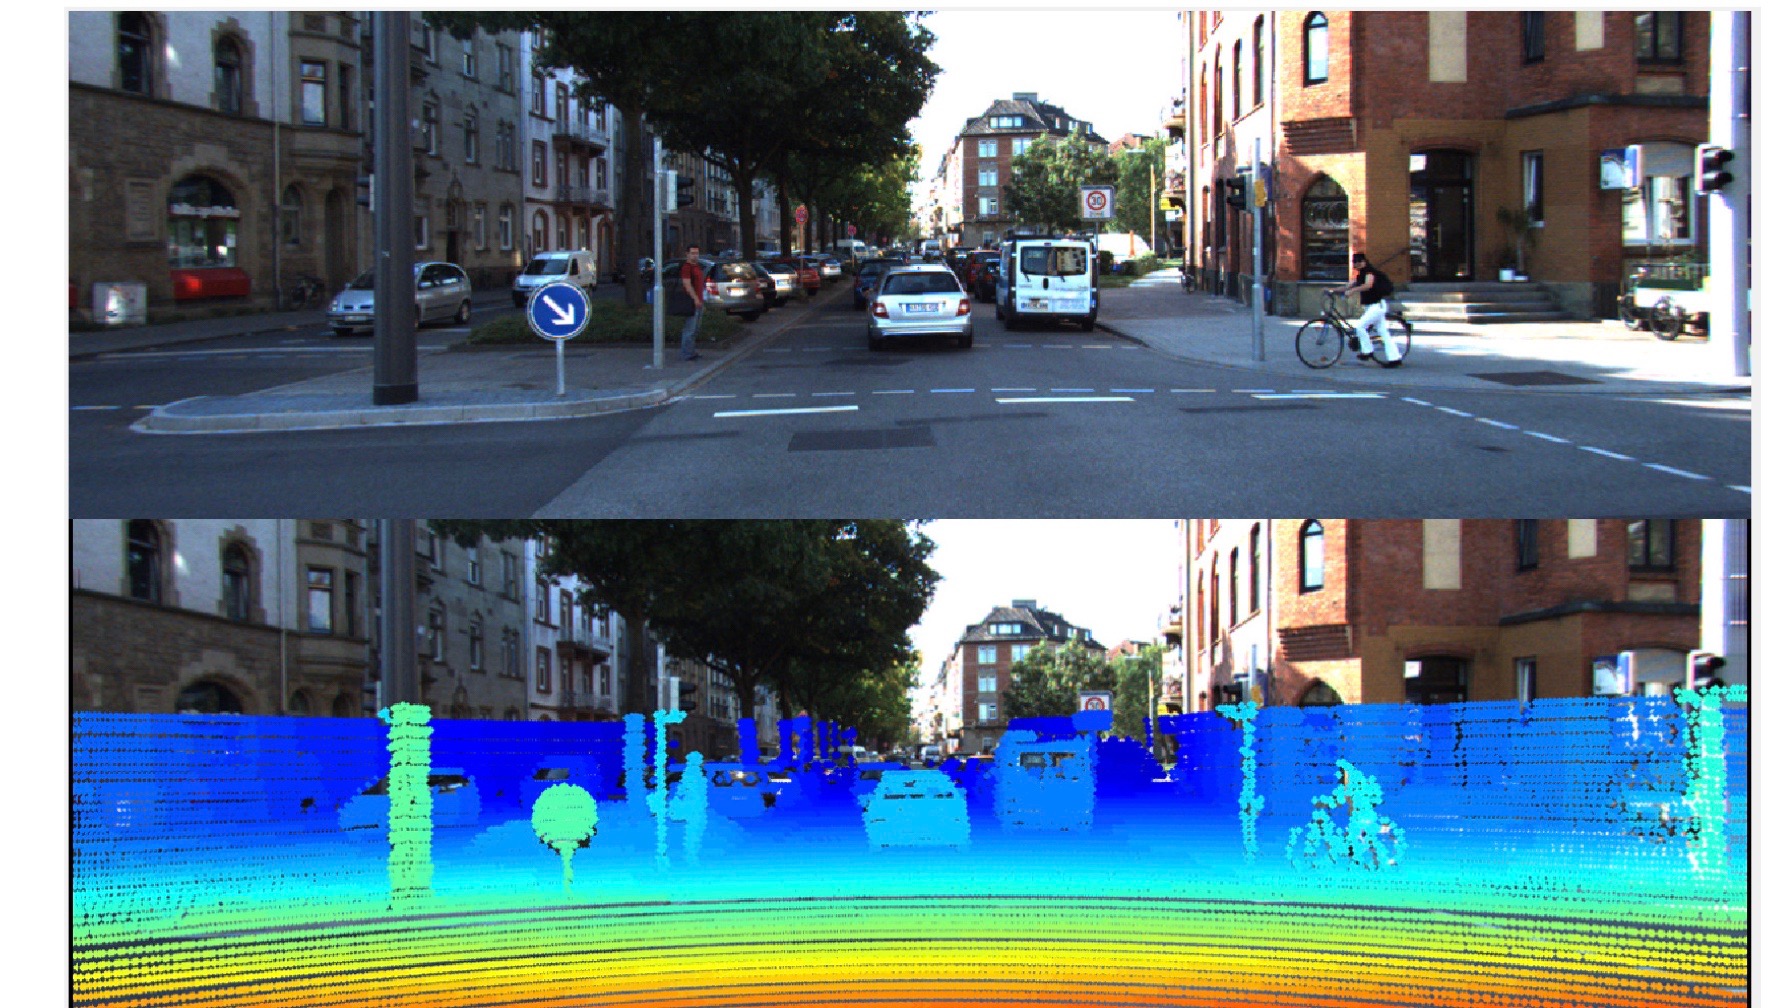
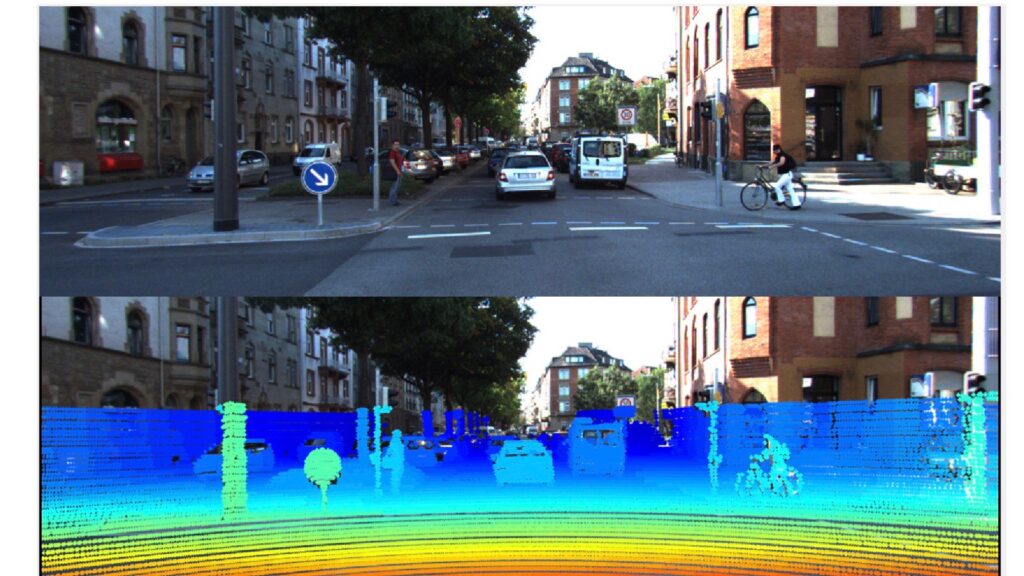
Object detection and recognition is a key component of autonomous robotic vehicles, as evidenced by the continuous efforts made by the robotic community on areas related to object detection and sensory perception systems. This paper presents a study on multisensor (camera and LIDAR) late fusion strategies for object recognition. In this work, LIDAR data is processed as 3D points and also by means of a 2D representation in the form of depth map (DM), which is obtained by projecting the LIDAR 3D point cloud into a 2D image plane followed by an upsampling strategy which generates a high-resolution 2D range view. A CNN network (Inception V3) is used as classification method on the RGB images, and on the DMs (LIDAR modality). A 3D-network (the PointNet), which directly performs classification on the 3D point clouds, is also considered in the experiments. One of the motivations of this work consists of incorporating the distance to the objects, as measured by he LIDAR, as a relevant cue to improve the classification performance. A new rangebased average weighting strategy is proposed, which considers the relationship between the deep-models performance and the distance of objects. A classification dataset, based on the KITTI database, is used to evaluate the deep-models, and to support the experimental part. We report extensive results in terms of single modality i.e., using RGB and LIDAR models individually, and late fusion multimodality approaches.
Citation
Gledson Melotti, Cristiano Premebida and Nuno Gonçalves. Multimodal deep-learning for object recognition combining camera and LIDAR data. In 2020 IEEE International Conference on Autonomous Robot Systems and Competitions (ICARSC) (pp. 177-182). IEEE. DOI: 10.1109/ICARSC49921.2020.9096138
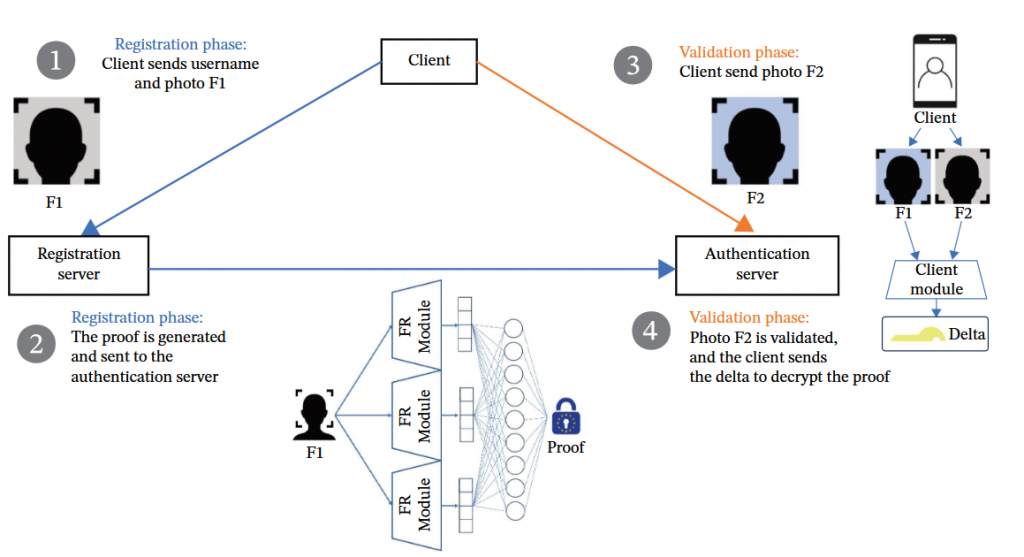
Towards Secure Biometric Solutions: A Multifactor Authentication Framework for Facial Recognition While Protecting User Data
Authors: José Silva; Ajnas Muhammed; Aniana Cruz; Bruno Sousa; Nuno Gonçalves
Featured in: IET Biometrics Volume 2026, Issue 1
Second Competition on Presentation Attack Detection on ID Card
Authors: Juan E Tapia; Mario Nieto; Juan M Espin; Alvaro S Rocamora; Javier Barrachina; Naser Damer; Christoph Busch; Marija Ivanovska; Leon Todorov; Renat Khizbullin; Lazar Lazarevich; Aleksei Grishin; Daniel Schulz; Sebastian Gonzalez; Amir Mohammadi; Ketan Kotwal; Sebastien Marcel; Raghavendra Mudgalgundurao; Kiran Raja; Patrick Schuch; Sushrut Patwardhan; Raghavendra Ramachandra; Pedro Couto Pereira; Joao Ribeiro Pinto; Mariana Xavier; Andrés Valenzuela; Rodrigo Lara; Borut Batagelj; Marko Peterlin; Peter Peer; Ajnas Muhammed; Diogo Nunes; Nuno Gonçalves
Featured in: 2025 IEEE International Joint Conference on Biometrics
DFIC: Towards a balanced facial image dataset for automatic ICAO compliance verification
Authors: Nuno Gonçalves; Diogo Nunes; Carla Guerra; João Marcos
Featured in: Submited to: ArXiv
suggested news
VIS Team will host a session presenting the...
Paper presented at NeurIPS 2025
VIS Team has presented workshop at the 12th...
RECENT PROJECTS
FACING2 – Face Image Understanding
VISUAL-ID – Unique Visual Identities in Graphics, Images and Faces
UniqueMark
Institute of Systems and Robotics Department of Electrical and Computers Engineering University of Coimbra